

Home | Contact Us | Submit Troubleshooting Info | Search | Help
Output | Software Solutions | Proofing | Color, Screening and Calibration | Scanning | Digital Photography | Consumables | POS
Home | Contact Us | Submit Troubleshooting Info | Search | Help
Output | Software Solutions | Proofing | Color, Screening and Calibration | Scanning | Digital Photography | Consumables | POS
Description | Parts | Procedures | Wiring | Theory of Operation | Connectors | Indicators | Hall Isolation Board
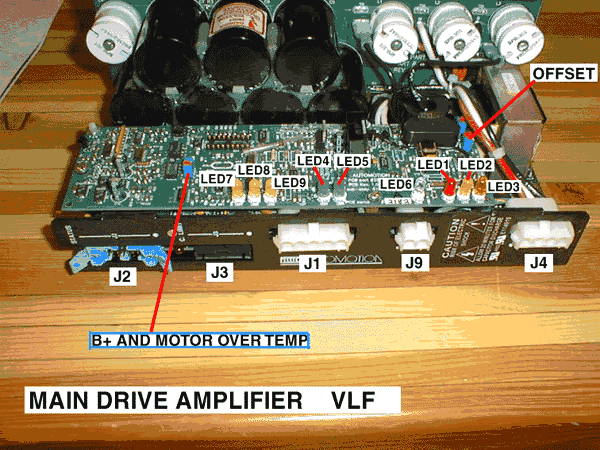
The drum drive amp receives control signals (torque demand) from the MPE firmware and provides controlled power to the drum motor.
A shunt resistor, located above the main drive amplifier (MDA), provides dynamic braking for faster response by dissipating the electricity generated from the kinetic energy of the drum during deceleration.
Input to the motor driver comes as a logic level, 5 kHz pulse width modulated. Motor current is controlled by varying the duty cycle of the incoming pulse train. Motor shaft position is fed back to the MDA from the Hall effect sensors inside the motor. A tachometer signal is fed back from the MDA to the MPE. The control software uses the tach signal for feedback during initialization and the drum encoder signal for feedback at all other times.
General VLF drum drive, encoder, and PLL
troubleshooting
Drum torque test
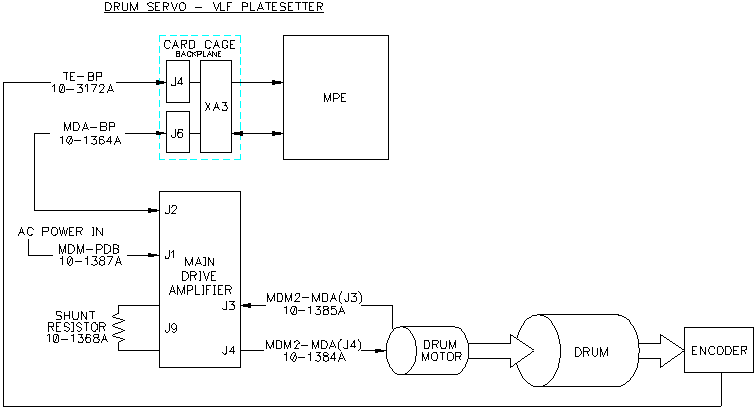
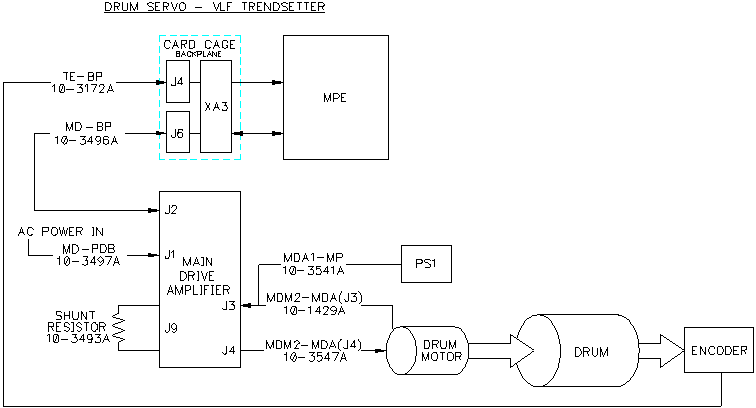
The drum drive amp is controlled by the MPE firmware which drives a 5 kHz pulse-width modulated signal into J2 on the drive amp. The duty cycle of this pwm signal is proportional to the output current driven into the motor, which is proportional to the torque generated by the motor. Three Hall effect sensors inside the motor feed back to the drive amp (J3), the motor shaft position, and the drive amp uses these to commutate the power waves (J4) to the motor. The drive amp also feeds back a combined signal from the Hall senseors to the MPE which the MPE uses to initialize the drum, spin the drum in hall mode (drum spin xxc) and as a crosscheck against the speed read from the encoder. The encoder is on the drum and feeds directly into the MPE.
This LED may flicker during high deceleration. If the C Limit LED latches ON with the status LED off, an over current fault has occured. This may be caused by a short in the cable or motor. Open the motor power connector and inspect joints. Measure the motor phase resistance and make sure all 3 phases are more or less balanced. If phase resistance varies by more than 50%, replace motor.
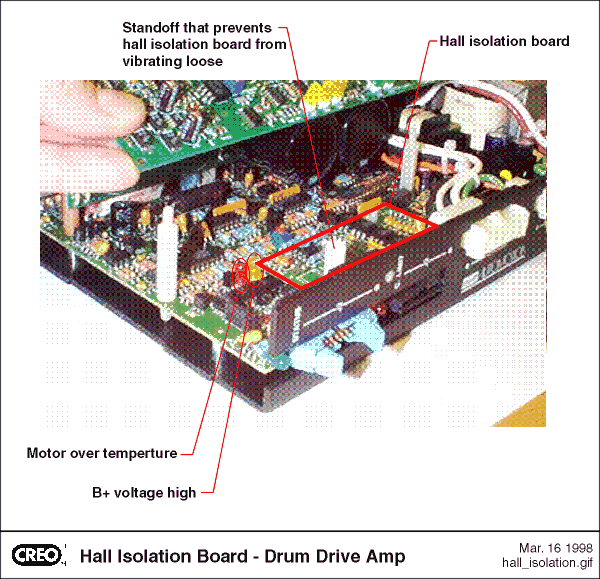
Newer drives have a opto coupled isolation board to isolate the Hall effect sensors in the motor from the safety low voltage in the platesetter. See identifying drive amps with the Hall Isolation Board.
| Connector | Description | Cable Name | Number |
| J1 | Power In. | MDM-PDB | 10-1387 |
| J2 | Control and sensor signals between MPE and MDA | MDA-BP | 10-1364 |
| J3 | Sensor input from the drum motor | MDM2-MDA (J3) | 10-1385 |
| J4 | Output signal to the motor stator windings Power input from PDB |
MDM2-MDA (J4) BPI-PDB |
10-1384 10-1352 |
| J9 | Shunt Resistor for braking | Drum resistor | 10-1368 |
| Pin | Signal |
| 1 | Logic power (hot) 230 VAC |
| 2 | Logic power (neutral) |
| 3 | Motor power (hot) 200-240 VAC |
| 4 | Motor power (neutral) |
| 5 | GND |
| Pin | MPE Signal | MDA Signal | Purpose |
| 1, 2 | +5 V | +5 V (input) | Logic supply for isolated I/O drivers |
| 3 | MD.ENBL | ENABLE (input) | Enables MDA output to motor |
| 4 | Reserved | ||
| 5 | MD.REV | REVERSE (input) | Changes motor direction |
| 6 | MD.BRAKE | BRAKE (input) | Enables dynamic braking |
| 7 | MD.FAULT | ENABLED (output) | Low during fault condition |
| 8 | MD.TACH | TACH (output) | Tach signal from motor sensors to MPE |
| 9, 10 | GND | GND | Return/common for control logic |
| 11 | MD.C PWM | CURRENT PWM (input) | Drive to motor PWM circuit |
| 12 | MD.AN+ | DIFF CURR. + (input) | Differential analog current drive input + |
| 13 | MD.AN- | DIFF CURR - (input) | Differential analog current drive input - |
| 14 | MD.CURR | CURRENT SIG. (output) | Proportional to output current |
| Pin | Signal |
| 1 | +15V Hall power |
| 2 | S1 |
| 3 | S2 |
| 4 | S3 |
| 5 | Hall common return |
| 6 | Motor over temperature |
| 7 | Motor over temperature |
| Pin | Signal |
| 1 | Motor frame ground |
| 2 | Phase 1 output |
| 3 | Phase 2 output |
| 4 | Phase 3 output |
| Pin | Signal |
| 1 | Shunt high |
| 2 | Shunt low |
| LED | Color | Indication |
| Status | Green | MDA operational and enabled |
| Current Limit | Red | Sourcing near maximum peak current (variable intensity) |
| 1 | Red | Overcurrent fault (latched condition) |
| 2 | Yellow | Current foldback/ attention |
| 3 | Orange | Current command (variable intensity) |
| 4 | Green | Direction toggle |
| 5 | Green | Direction toggle |
| 6 | Green | Logic power OK |
| 7 | Yellow | Hall S1 |
| 8 | Yellow | Hall S2 |
| 9 | Yellow | Hall S3 |
| Motor overtemp | Red | Over temperature LED is located behind J2 |
| Over voltage | Yello | B+ voltage high LED is located behind J2 |
Normal LED Sequence
For VLF engines (with custom servo motors and ALC 20D drive amps), Hall
effect commutation sensors are 120 degrees apart.
| LED 7 | LED 8 | LED 9 |
| off | off | on |
| on | off | on |
| on | off | off |
| on | on | off |
| off | on | off |
| off | on | on |
| Invalid states | ||
| LED7 | LED8 | LED9 |
| on | on | on |
| off | off | off |
All three LEDs are never on or off at the same time. On older drive amps, if either of these states is detected then a fault is generated. (error 6011). If the drum is rotated slowly by hand, each yellow LED should change state at least once within a motor revolution.
See Hall Sensor Problems.